Tongmiao XuI am a second-year master's student in Computer Science at UIUC advised by Prof. Svetlana Lazebnik and Prof. Yunzhu Li. I was a teaching assistant for Data Science Discovery in fall 2025 and Database Systems in spring 2026. In summer 2026 I was a robot learning intern at SceniX/WorldLabs, building sim-to-real pipelines for xArm manipulation trained entirely on simulated data. I got my BS in ME and EECS at Xi'an Jiaotong University in 2025 advised by Prof. Xiang Li. I was also fortunate to be advised by Prof. David Hsu at the AdapComp Lab, School of Computer Science in NUS. My research interests lie in advancing robotic manipulation and interaction with the physical world through efficient control, estimation, and learning algorithms. |
|
Publication
|
|
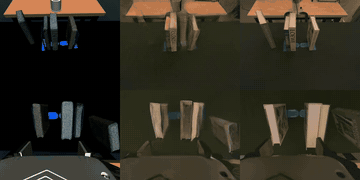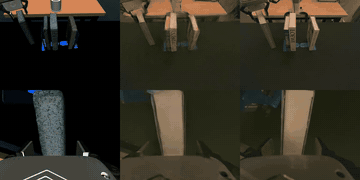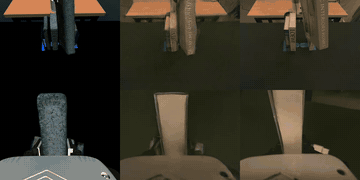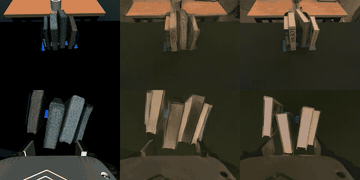
STRIPE: Sim-to-Real Image Translation for Real-to-Sim Policy EvaluationTongmiao Xu*, Shivansh Patel*, Svetlana Lazebnik (*equal contribution) Under review at ICRA 2027, 2026 website / We present a real-to-sim policy evaluation framework that combines mesh-based scene reconstruction in MuJoCo, calibrated robot dynamics, and STRIPE, a learned image translator that maps simulated renders to real-camera appearance while preserving spatial layout. Across four manipulation tasks and four policy families (ACT, Diffusion Policy, GR00T N1.5, π0.5), STRIPE gives stronger sim-to-real success-rate correlation and policy rank agreement than raw rendering, classical color alignment, or Pix2Pix. |
|
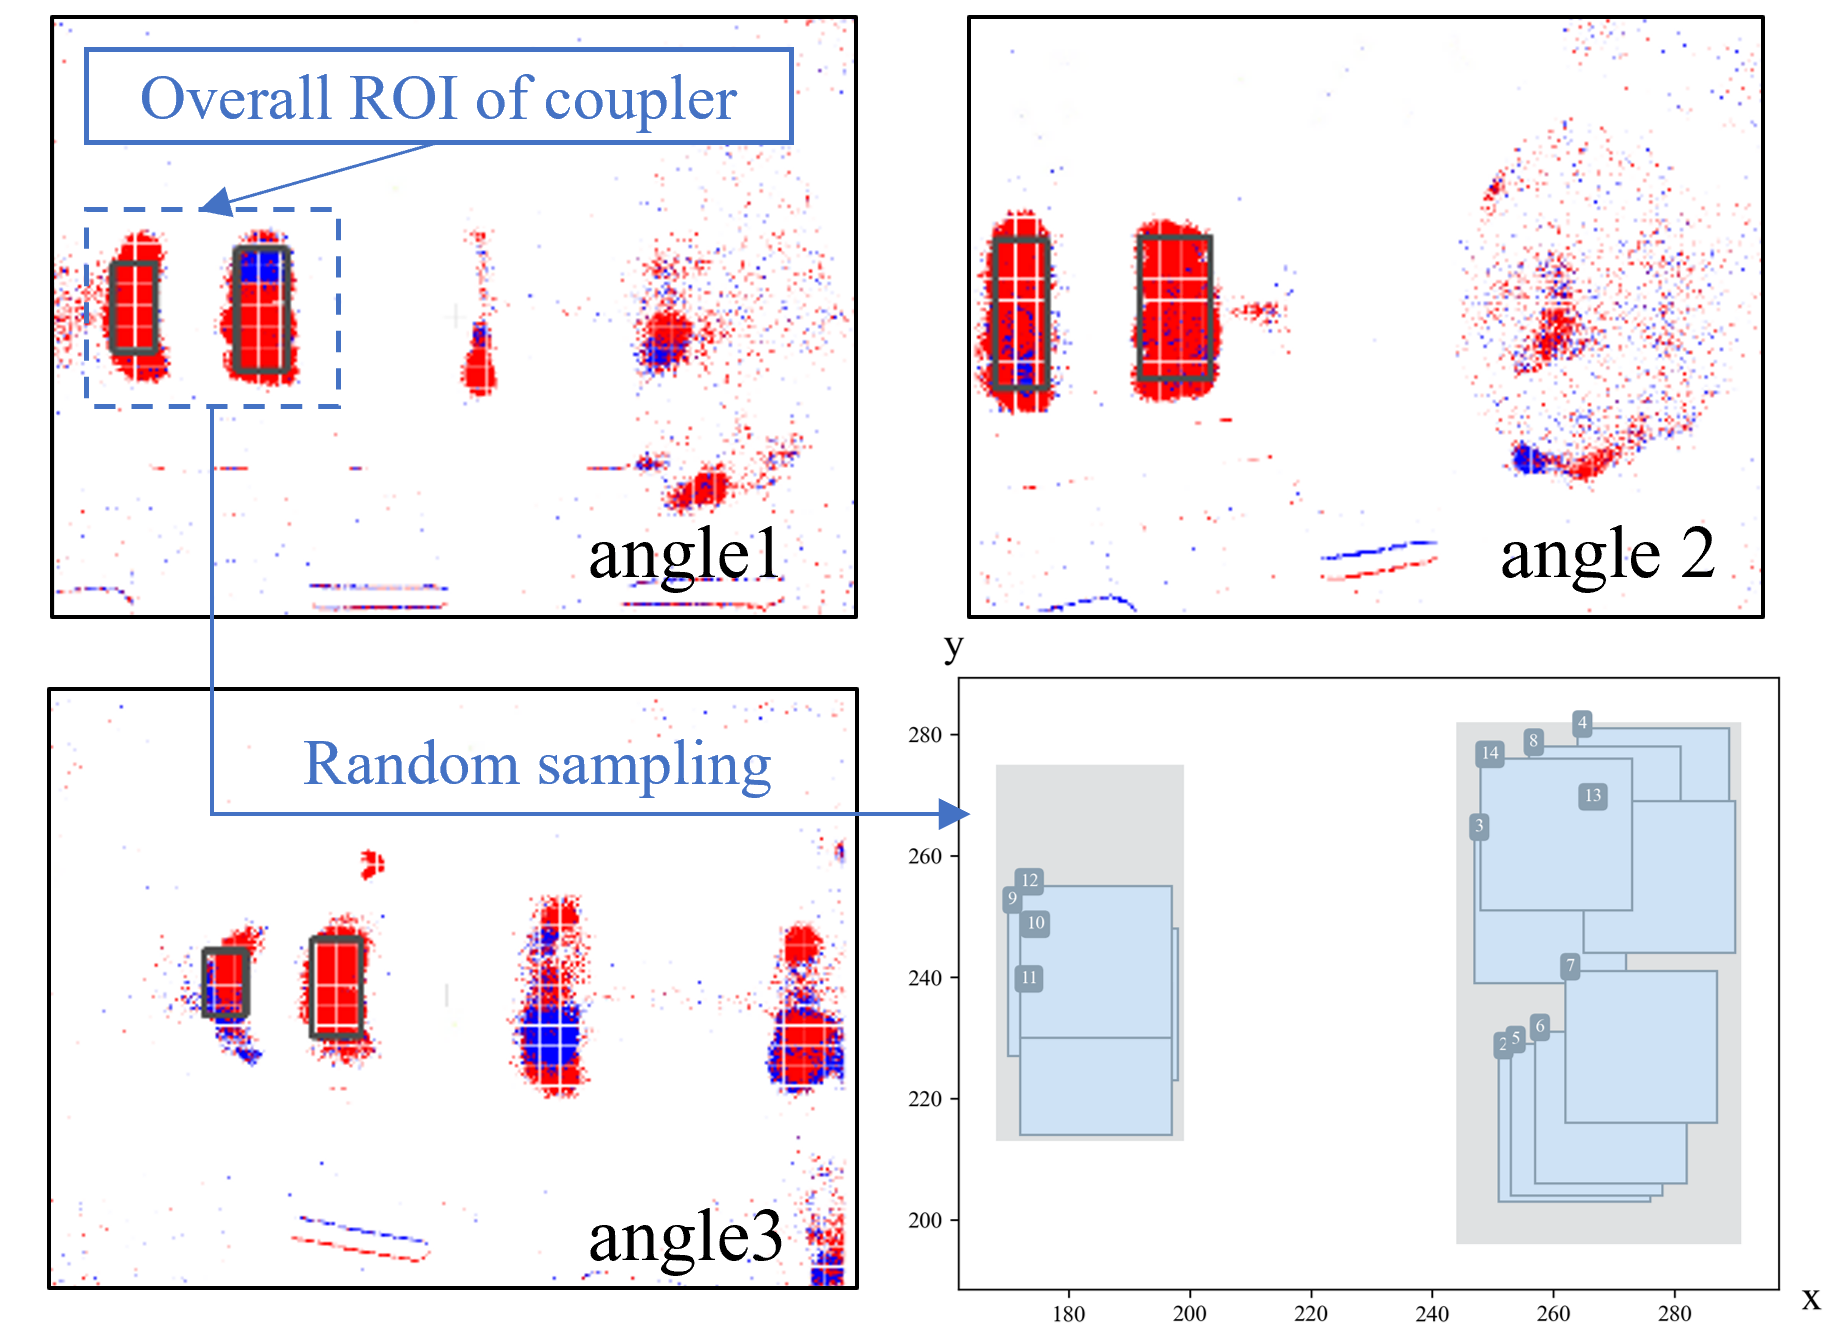
Dynamic Vision-Enabled Machine Condition Monitoring: A Point Cloud-Based Diagnostic MethodologyTongmiao Xu, Dehao Cai, Shaojie Yang, Shuai Gu, Xiang Li 2024 IEEE Global Rel&PHM-Beijing, 2024 paper / video / code This paper is about the application of event cameras as Dynamic Vision Sensors for machine fault diagnosis, classifying bearing states as healthy, inner race fault, ball fault, or outer race fault using a deep learning-based classification method (PointNet ++ ) |
Research Projects |
|
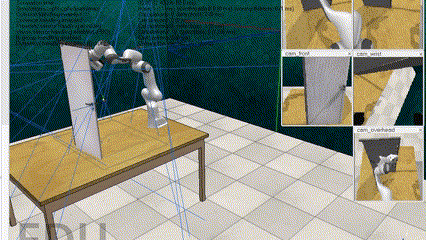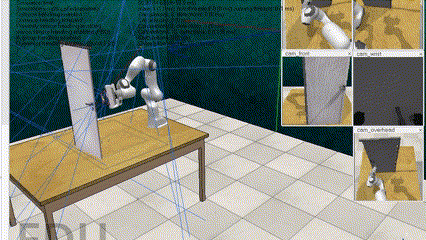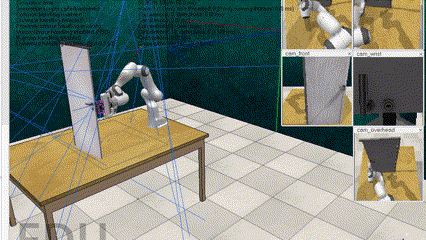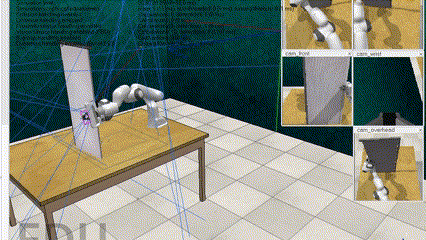
CORE: Canonical Object Representations for Enhanced ManipulationAdapComp Lab, NUS (advised by Dr. Hanbo Zhang and Prof. David Hsu) B.S. Thesis, 2025 · 2025 EEML Best Poster Award website / thesis / video / poster / code Imitation-learned policies break when the camera view or object placement changes. CORE decouples vision-based decision making from robot execution with a contact-anchored canonical object frame: point clouds and end-effector actions are expressed in that frame, so one policy generalizes across camera viewpoints, object placements and robot kinematics. On RLBench door opening it reaches 95% success on unseen placements, versus 30% for ACT and 15% for DP3. |
Selected ProjectsThese include coursework and side projects. |
|
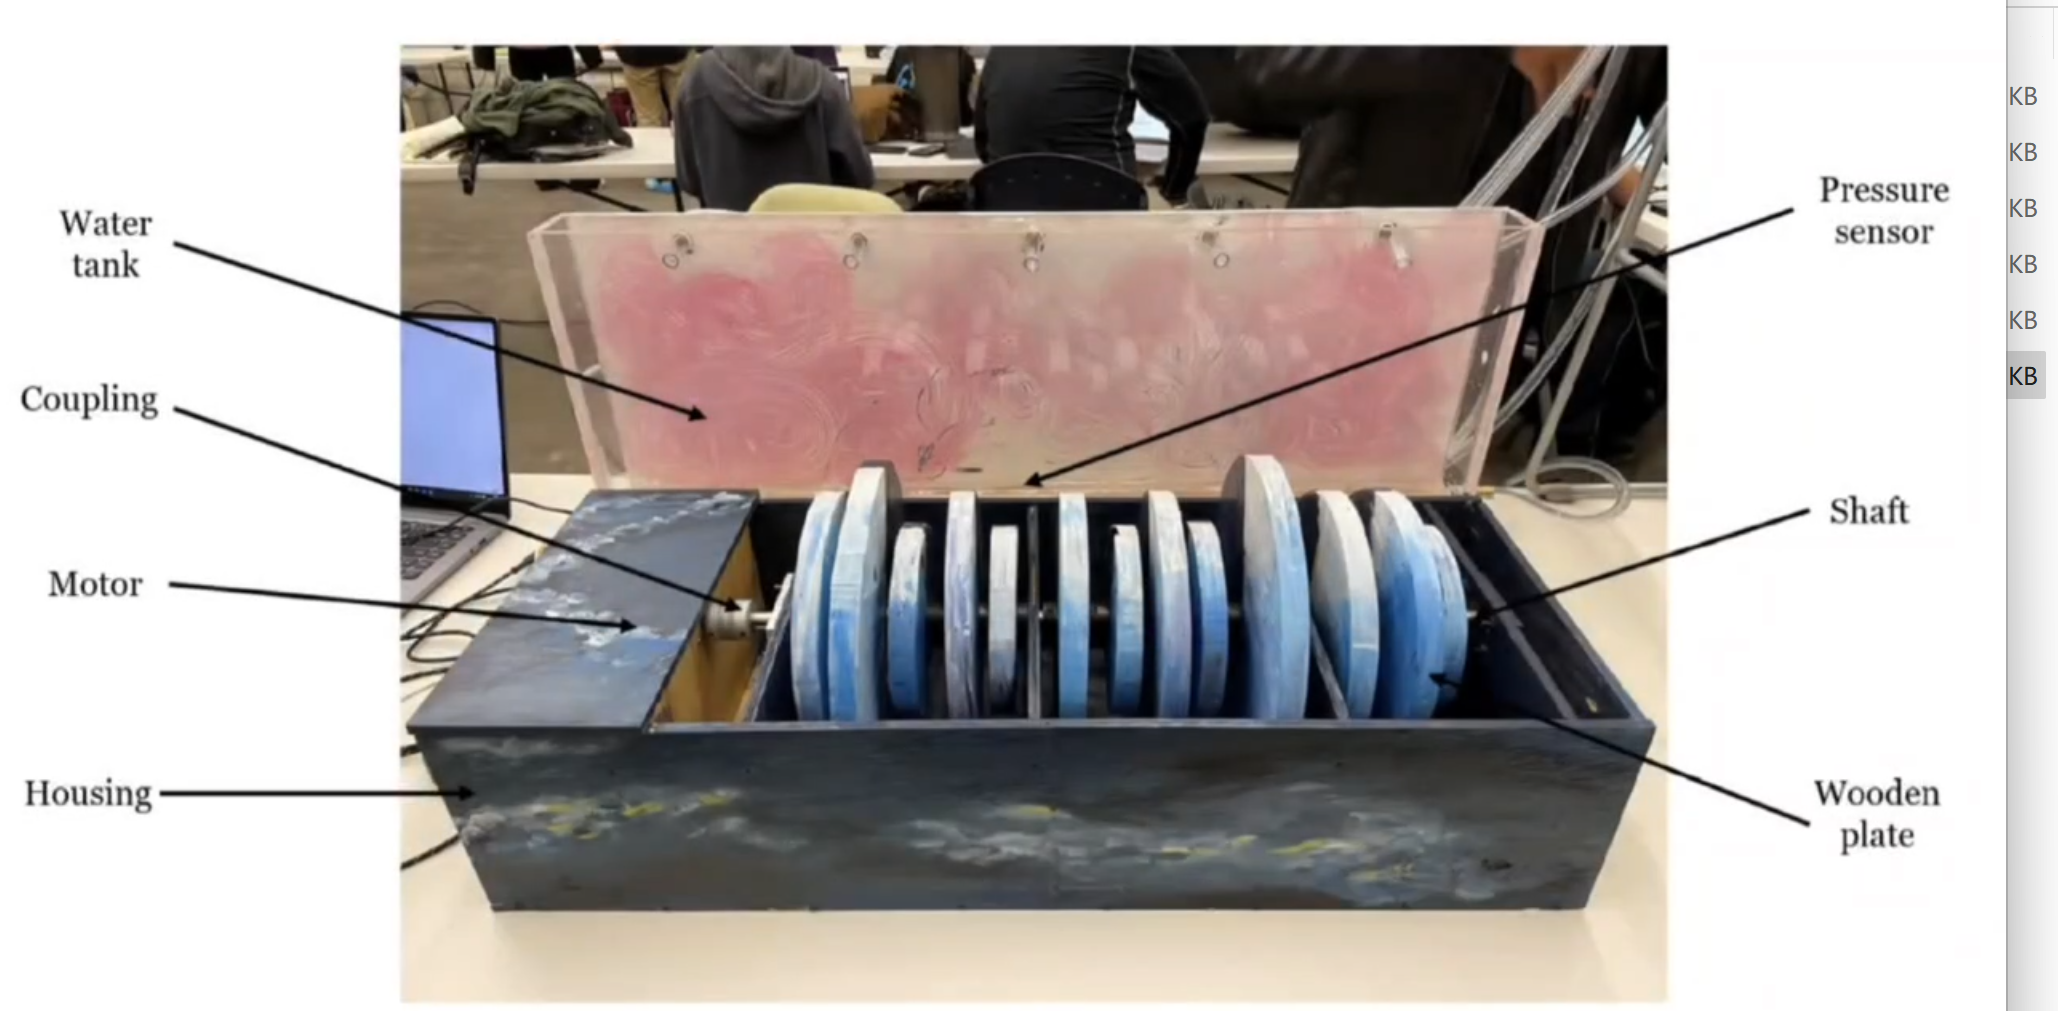
Tears of Ocean: A Mechatronic Art InstallationUC Berkeley ME102B Mechatronic Design 2023-12-16 video / poster / code This project was awarded the Second Prize in Mechatronics Design Social Impact at UC Berkeley. By combining engineering principles with artistic vision, this project consists of a smooth and accurate control system based on haptic feedback and highlights the potential of mechatronics in creating impactful, interactive art installations. |
|
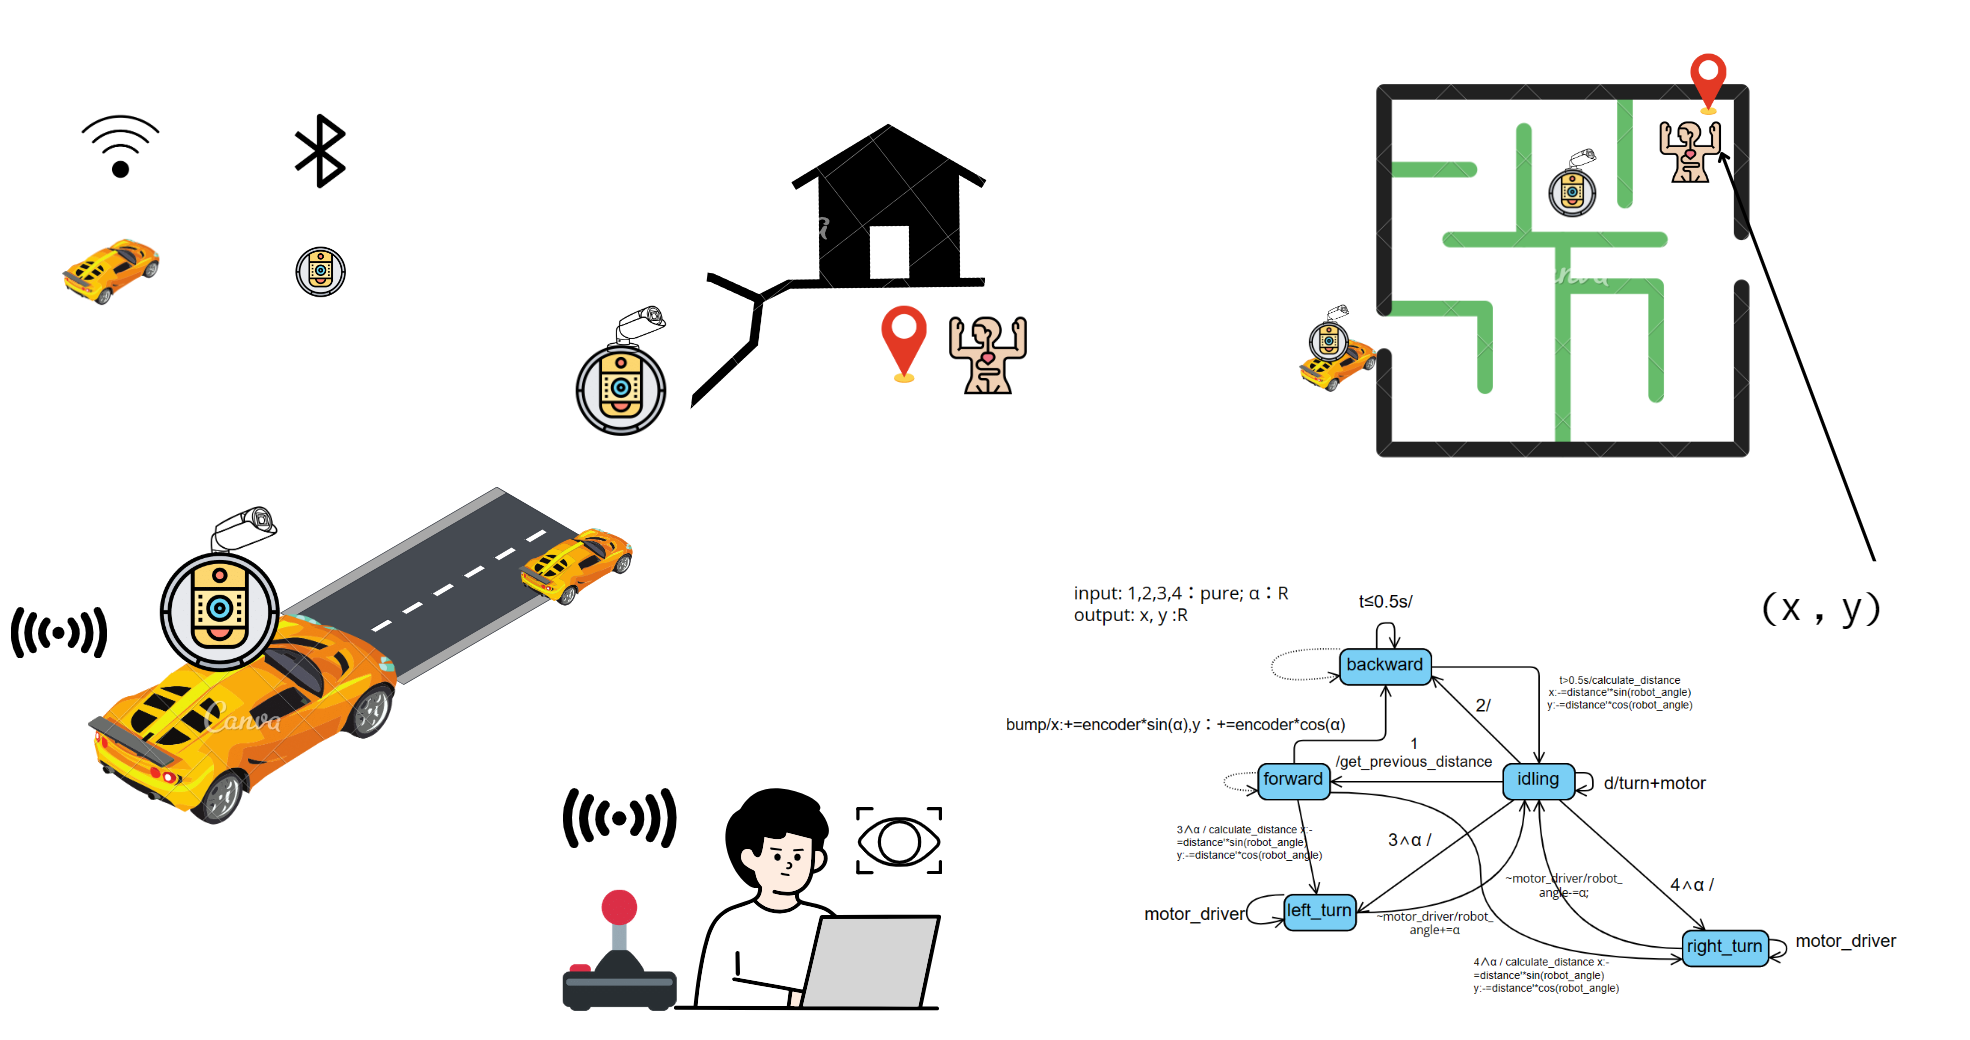
Raspberry Pi Based Bluetooth Rescue RoverUC Berkeley EECS149 Introduction to Embedded & Cyber-Physical Systems 2023-11-10 code This project enhances the 3pi+ 2040 robot by enabling Bluetooth-based motion control using an HC-05 module. A finite state machine (FSM) manages the robot’s operations, while gyroscopes provide localization for accurate navigation and adaptive performance. |
|
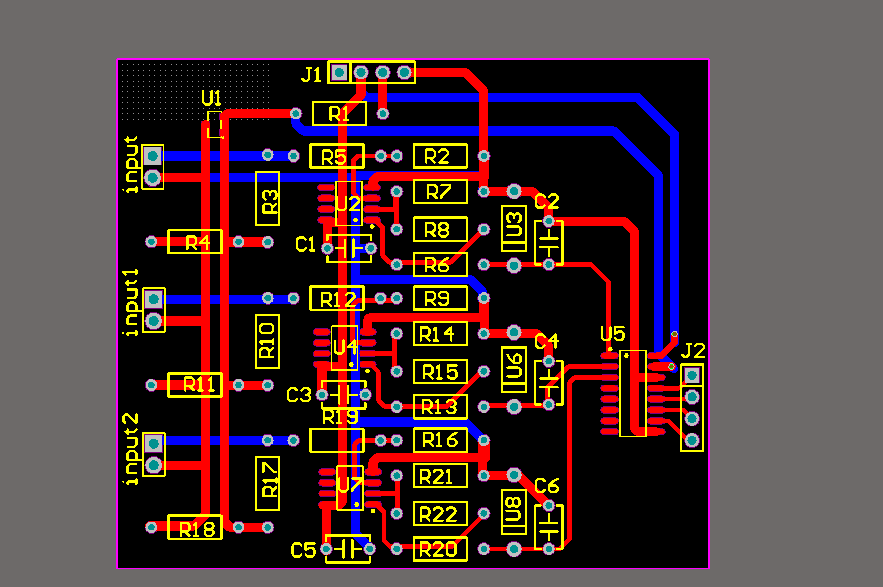
Akashi Cup Resistance Sensor System DesignXJTU Mechanical Engineering Innovation Competition 2024-08-27 news This project, which earned First Prize in the 2024 China College Students Mechanical Engineering Innovation and Creativity Competition, focused on developing a high-accuracy resistance measurement system. It involved designing an optimized PCB circuit board and deploying an embedded application on a Raspberry Pi 3 Model B, ensuring efficient and reliable performance. |
|
|