Dynamic Vision-Enabled Machine Condition Monitoring: A Point Cloud-Based Diagnostic Methodology
Xi'an Jiaotong University · 2024 IEEE Global Reliability & PHM Conference (PHM-Beijing)
Abstract
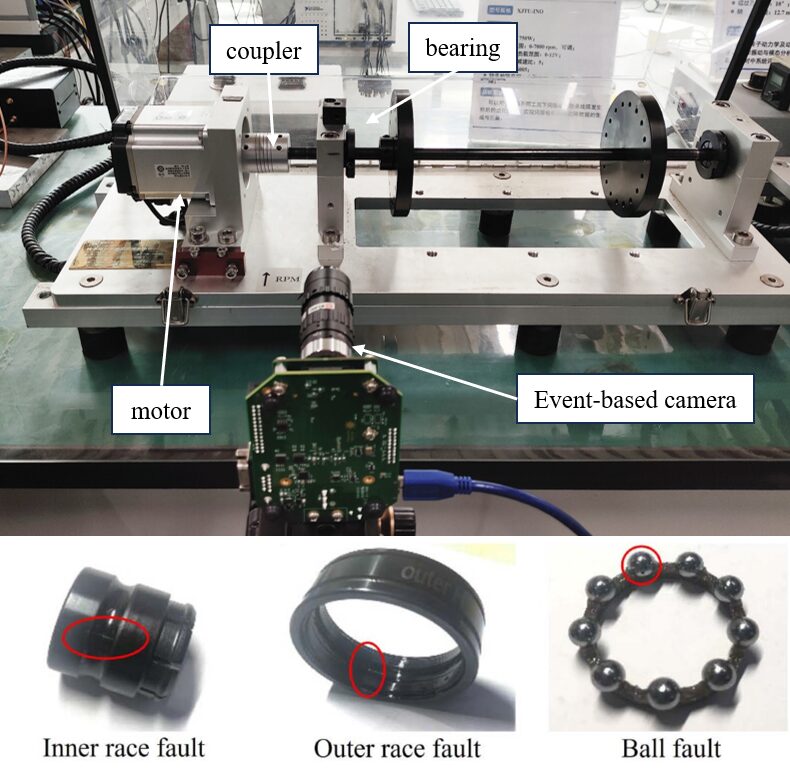
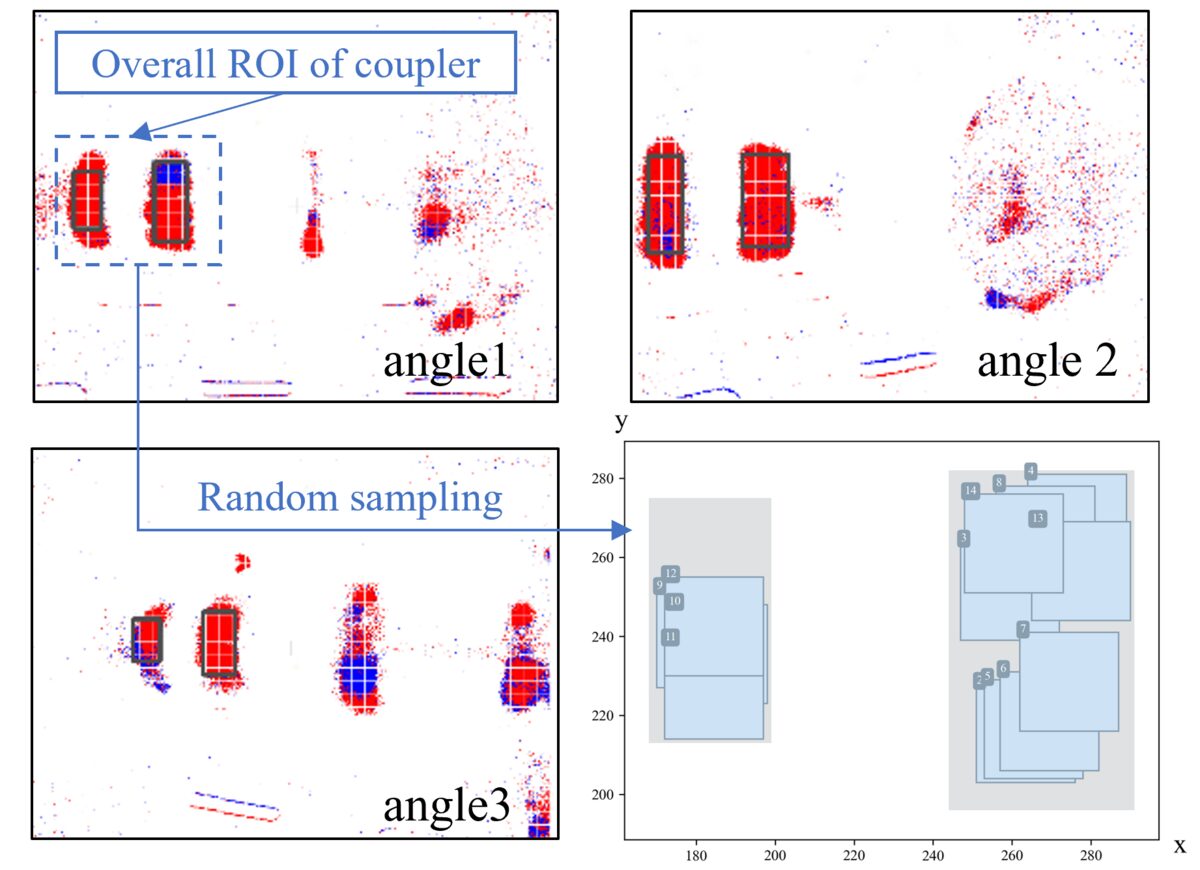
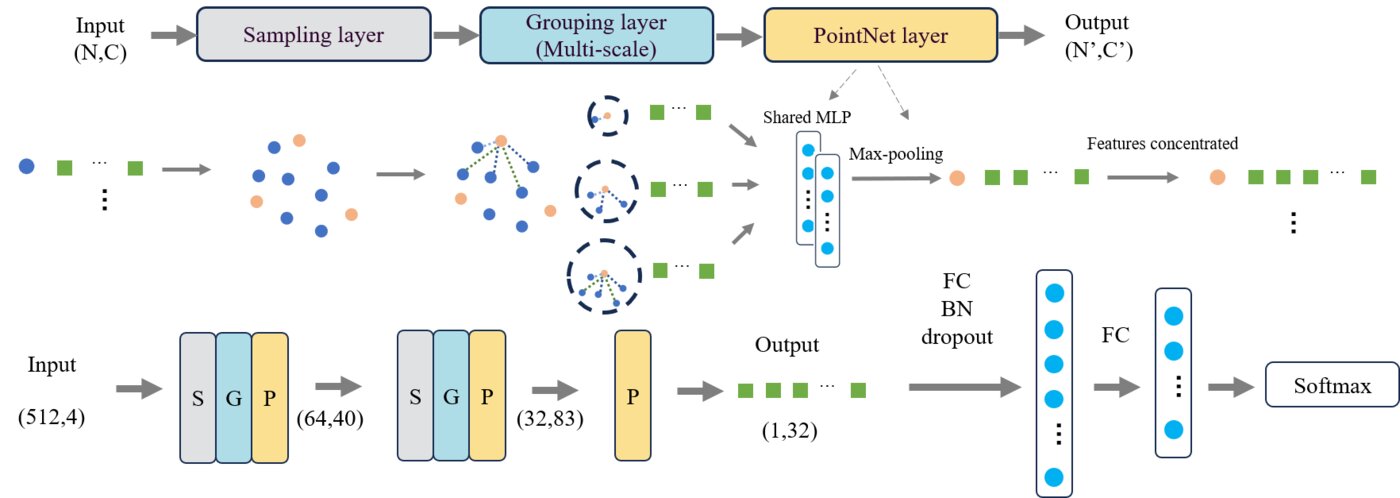
This work is one of the first to use a 3D point cloud algorithm on event data for machine fault diagnosis. Event cameras (Dynamic Vision Sensors) report per-pixel brightness changes with microsecond timing, instead of full frames. We represent each slice of the event stream as a geometric point cloud over (x, y, t), then classify it with a deep point cloud network (PointNet++). We test the method on diagnosing faults in a rotating machine with an event camera.
SensorEvent camera (DVS)
RepresentationEvents as (x, y, t) point clouds
ModelPointNet++ classifier
ClassesHealthy · inner race · outer race · ball
Events as point clouds
Network
Talk
Citation
@inproceedings{xu2024dynamic,
  title     = {Dynamic Vision-Enabled Machine Condition Monitoring:
               A Point Cloud-Based Diagnostic Methodology},
  author    = {Xu, Tongmiao and Cai, Dehao and Yang, Shaojie and Gu, Shuai and Li, Xiang},
  booktitle = {2024 Global Reliability and Prognostics and Health Management Conference (PHM-Beijing)},
  year      = {2024}
}