SceniX (now World Labs): Real-to-Sim-to-Real
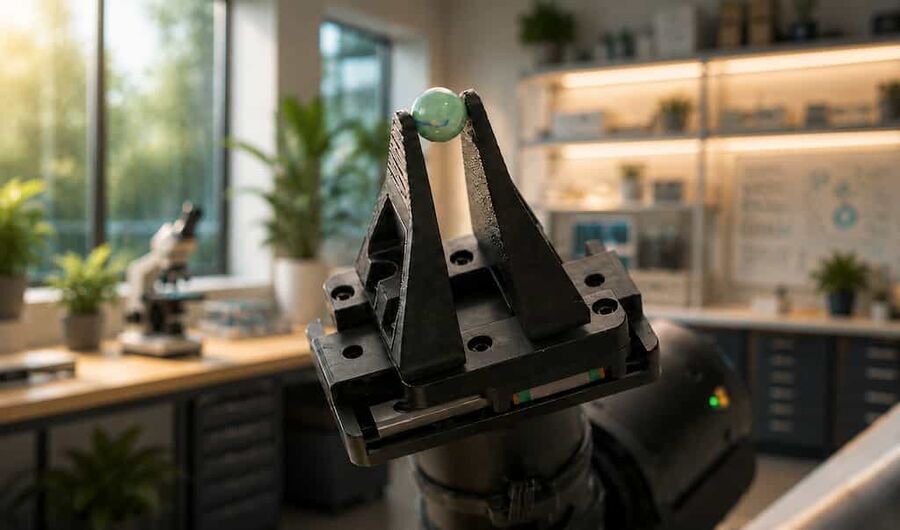
I led the pencil singulation task. I built its full sim-to-real stack on the xArm. Policies trained on zero real-world data ran autonomously for 1 hour at 159 pencils/hr.
Robot learning · sim-to-real · manipulation
MS CS @ UIUC
Industry · 2026
SceniX (now World Labs): Real-to-Sim-to-Real
I led the pencil singulation task. I built its full sim-to-real stack on the xArm. Policies trained on zero real-world data ran autonomously for 1 hour at 159 pencils/hr.
STRIPE: Sim-to-Real Image Translation
Real-to-sim policy evaluation with a learned translator that makes sim renders look like the real camera.
CORE: Canonical Object Representations
One manipulation policy that generalizes across camera views, object placements and robots. 95% success on unseen placements.
Research · 2024
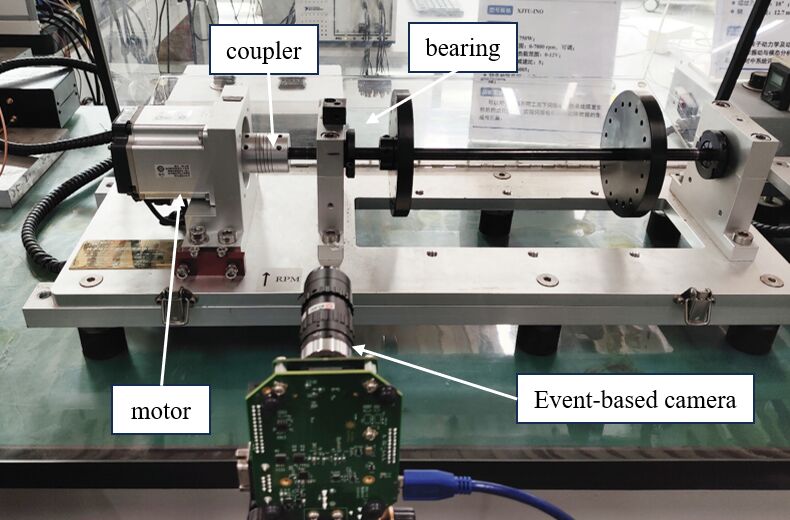
Event-Camera Machine Condition Monitoring
Diagnosing bearing faults from event-camera streams, treated as 3D point clouds and classified with PointNet++.
Mechatronics · 2023
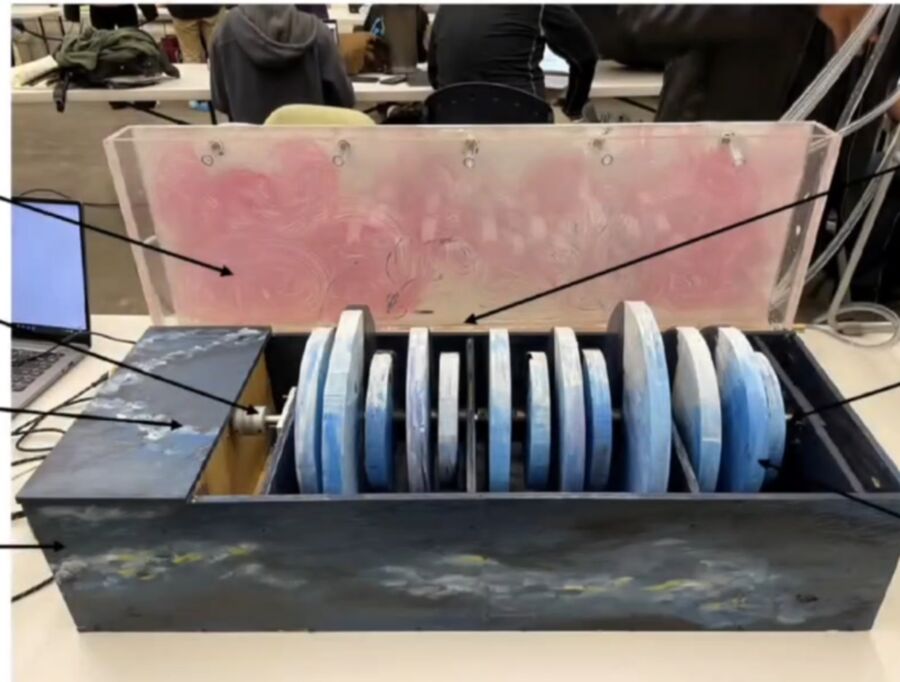
Tears of Ocean
A kinetic art installation about ocean pollution, built at UC Berkeley with PID motor control and force sensing.